Zhenjun Zhao (赵祯俊)
I am a postdoctoral researcher at University of Zaragoza, working with Javier Civera.
I received my PhD from the Chinese University of Hong Kong (CUHK), under the supervision of Ben M. Chen.
My research focuses on certifiable global optimization and robust estimation for 3D geometric perception, aiming to develop solvers that are globally optimal, outlier-robust, and computationally efficient. I work on problems across camera geometry estimation, Structure-from-Motion, SLAM, and visual localization, with a particular interest in bridging the gap between optimization theory and real-world robotic perception. My long-term goal is to build trustworthy geometric perception systems that provide strong correctness guarantees while remaining practical for deployment in complex, dynamic environments.
News
- 10/2026 Grant: I am awarded a Marie Skłodowska-Curie Actions Postdoctoral Fellowship (MSCA-PF 2025) by the European Commission for the project TRUST-VSLAM at the University of Zaragoza!
- 10/2026 Invited to give a talk on Trustworthy Geometric Perception at Fauna, Amazon.
- 09/2026 Invited to give a talk on Trustworthy Geometric Perception at Eastern Institute of Technology, Ningbo.
- 07/2026 Invited to give a talk on Trustworthy Geometric Perception at Best of ICRA.
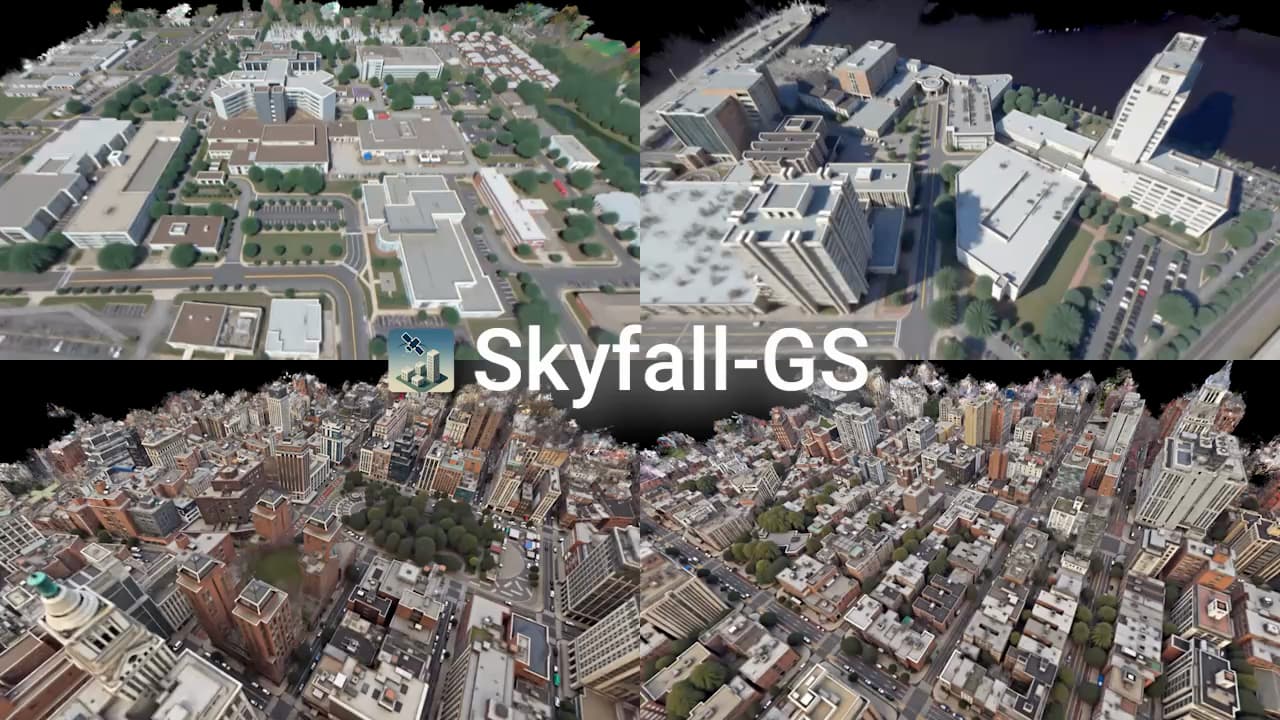
- 06/2026 Our paper MyGO-Splat is accepted to IROS 2026! Our paper Skyfall-GS is accepted to ECCV 2026!
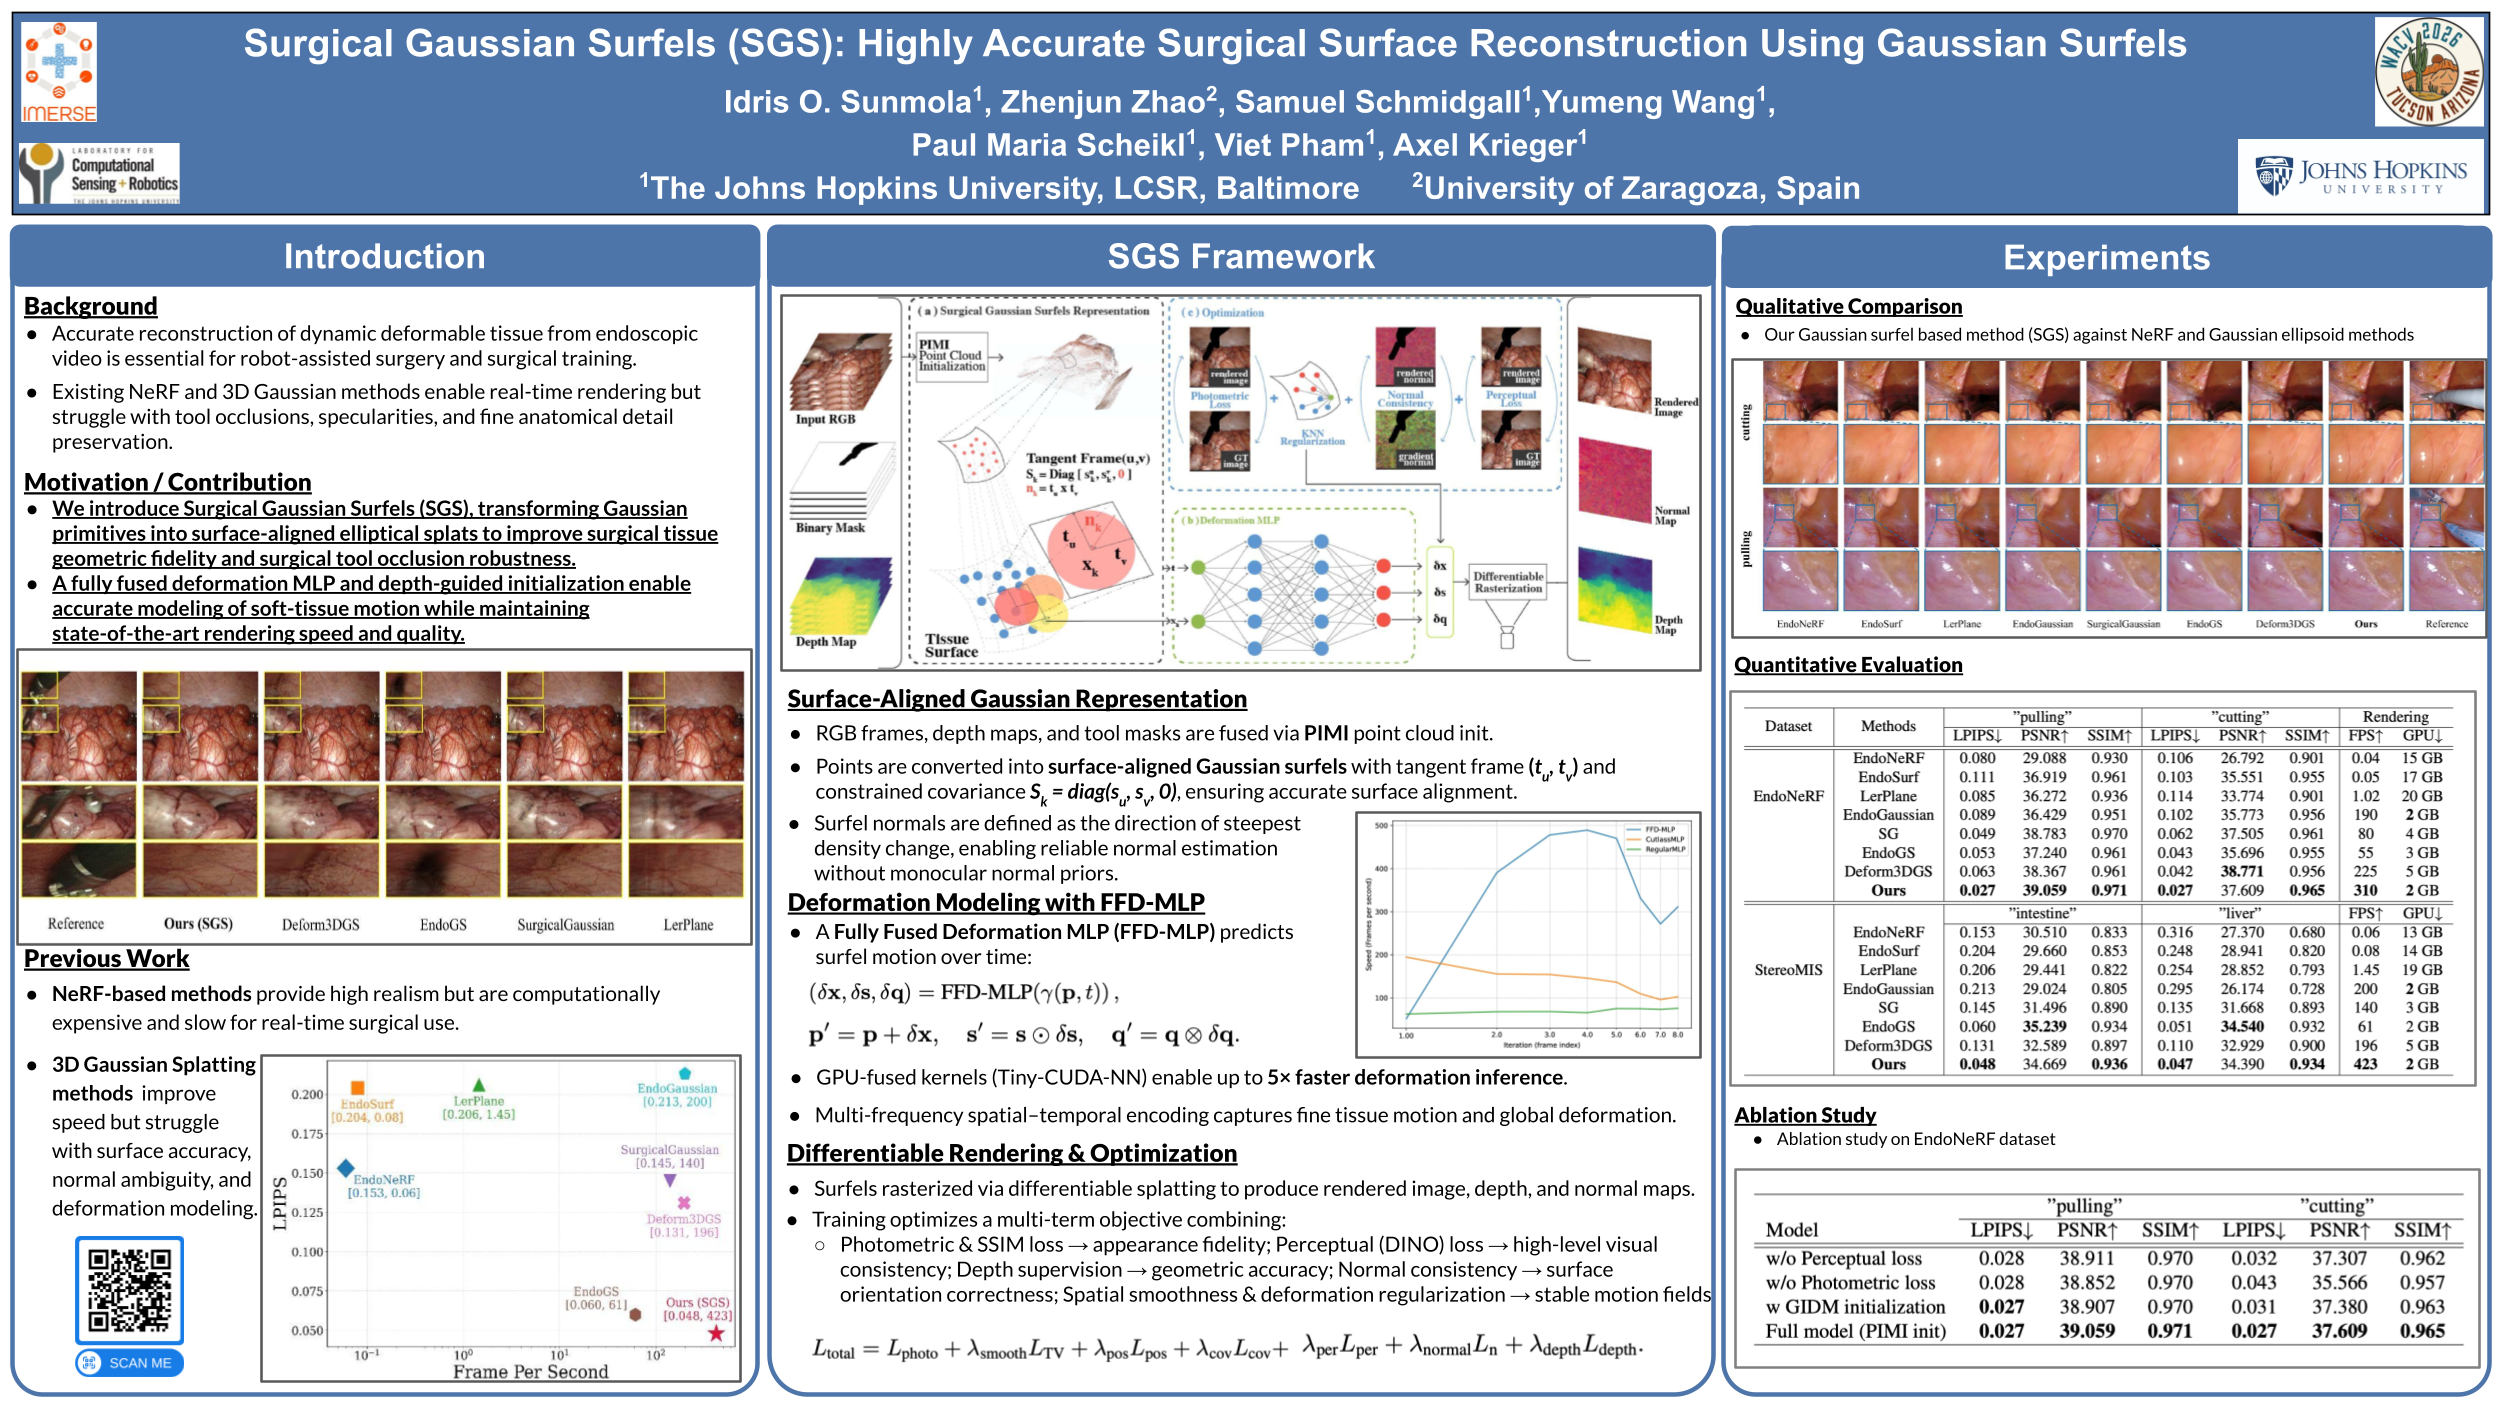
- 06/2026 Our paper SGS receives the Best Paper Award at SPAR-3D Workshop @ CVPR 2026!
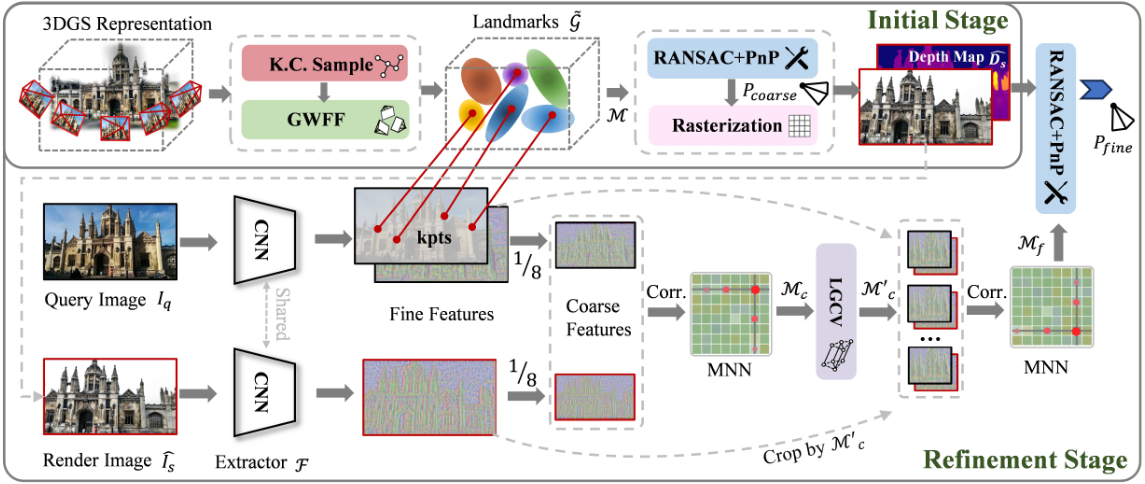
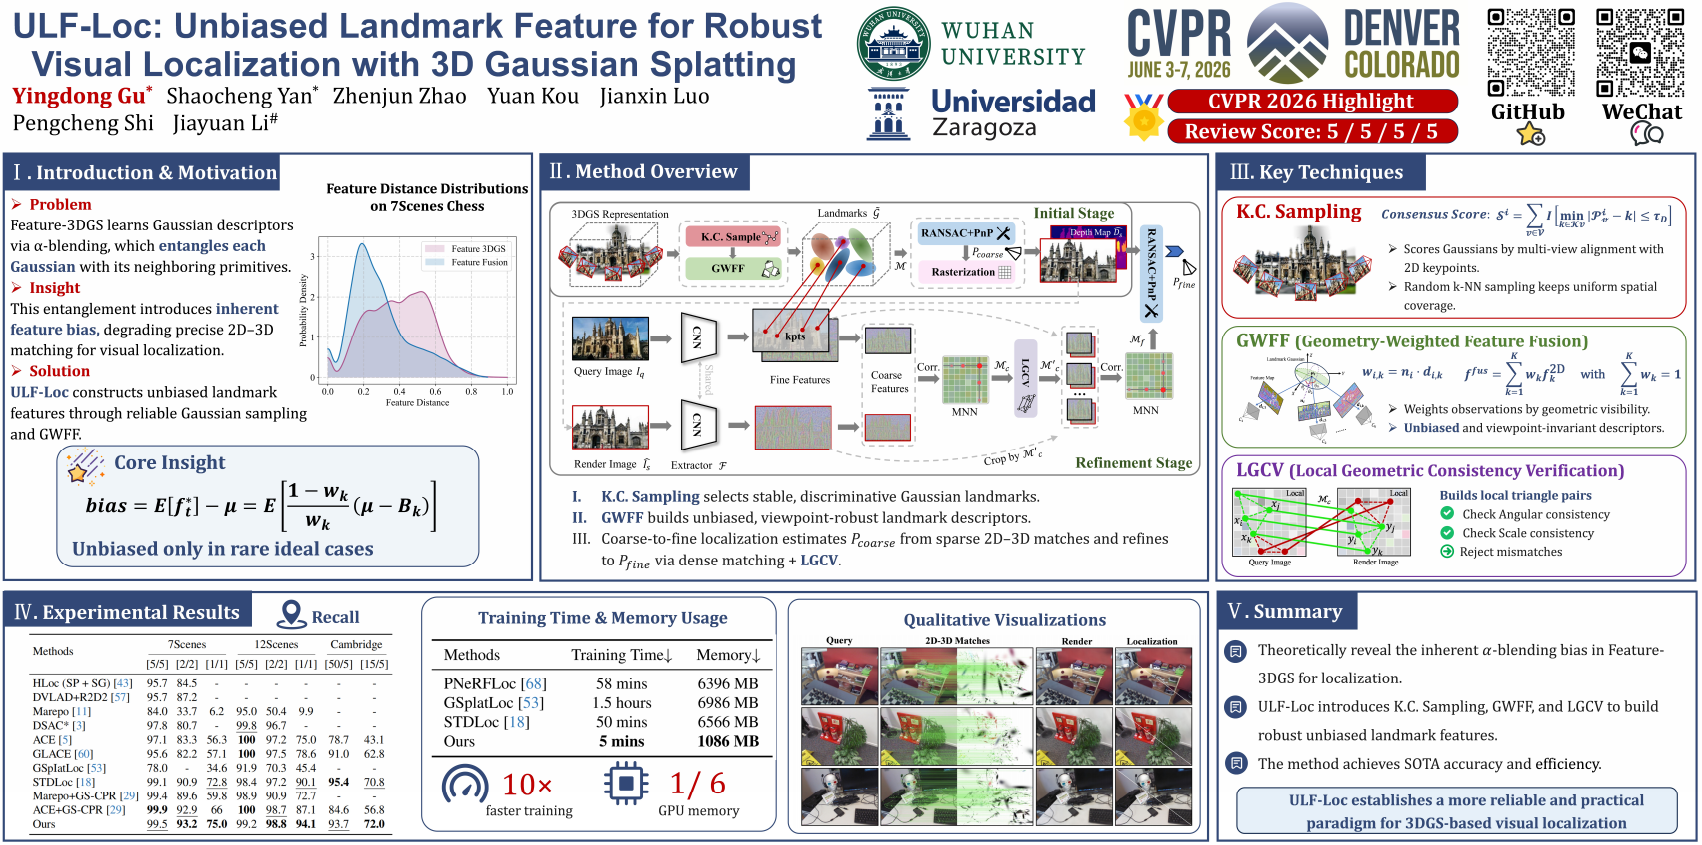
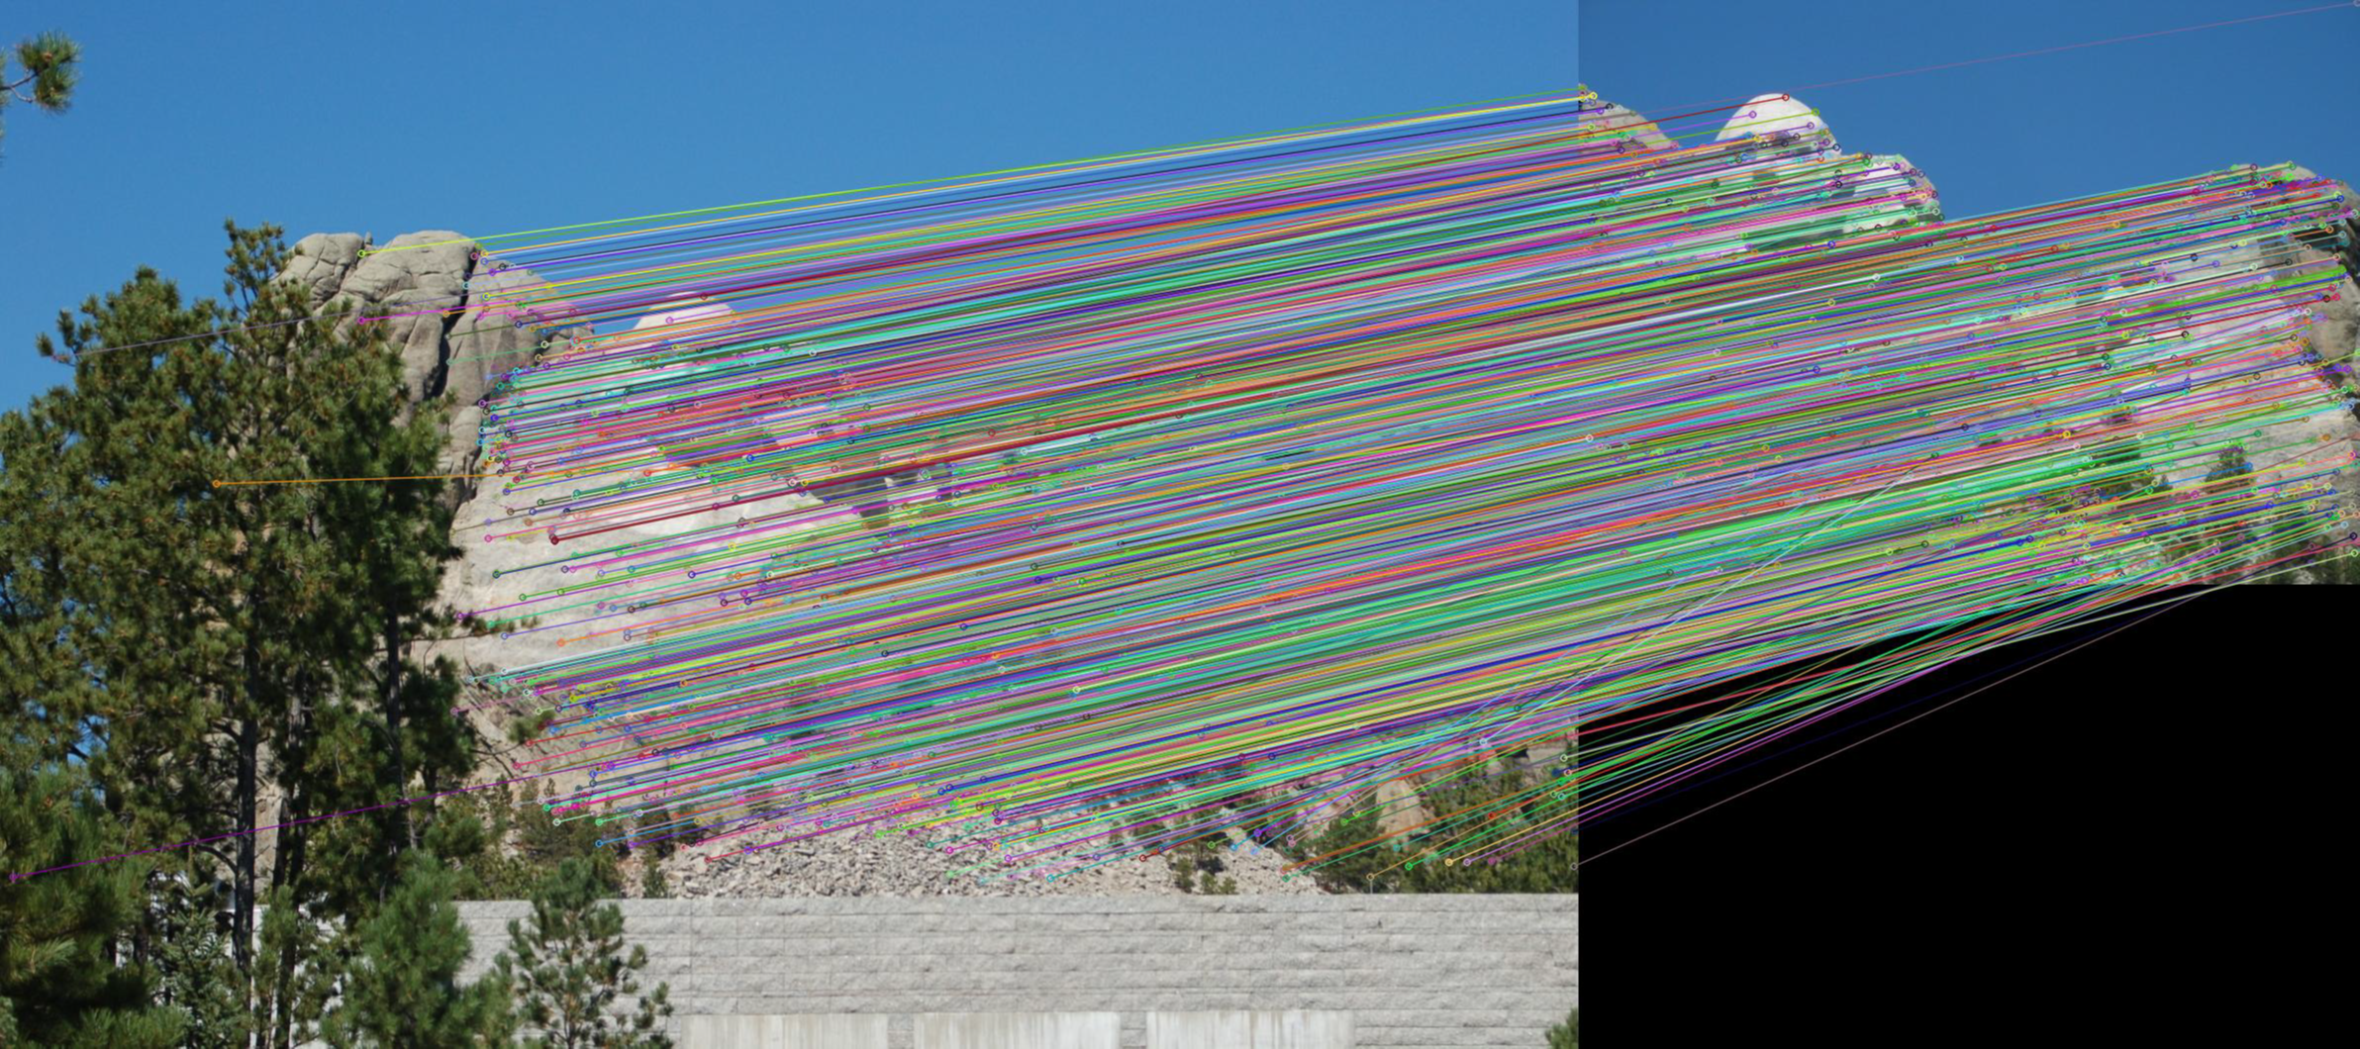
- 04/2026 Our paper ULF-Loc is selected as Highlight by CVPR 2026!
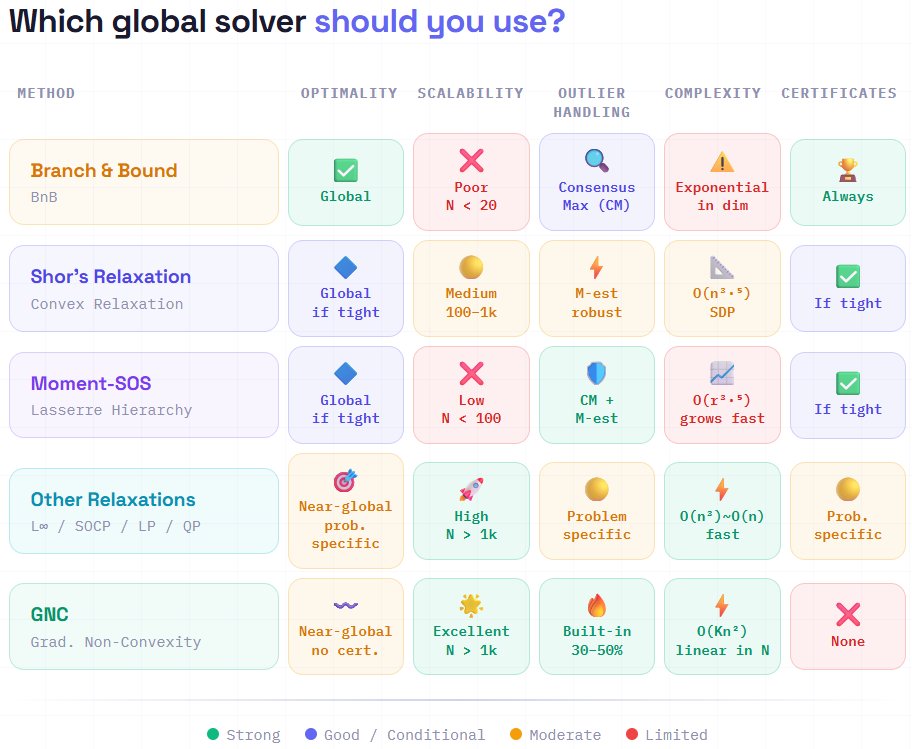
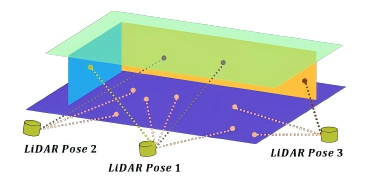
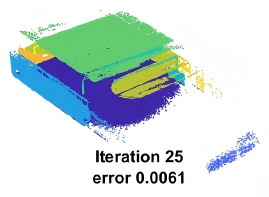
- 03/2026 Our paper Global Solvers for 3D Vision is accepted to ICRA 2026 Workshop!
- 02/2026 Our paper ULF-Loc is accepted to CVPR 2026! Our paper AdaGaR is accepted to CVPR Findings 2026!
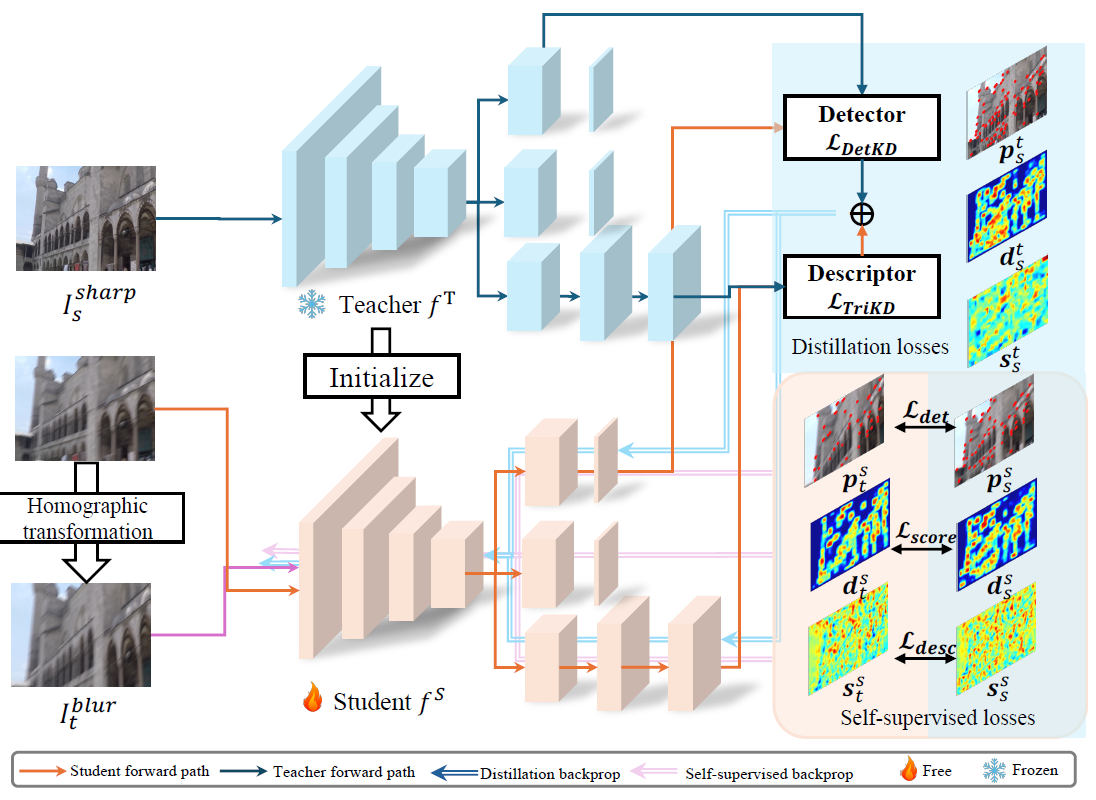
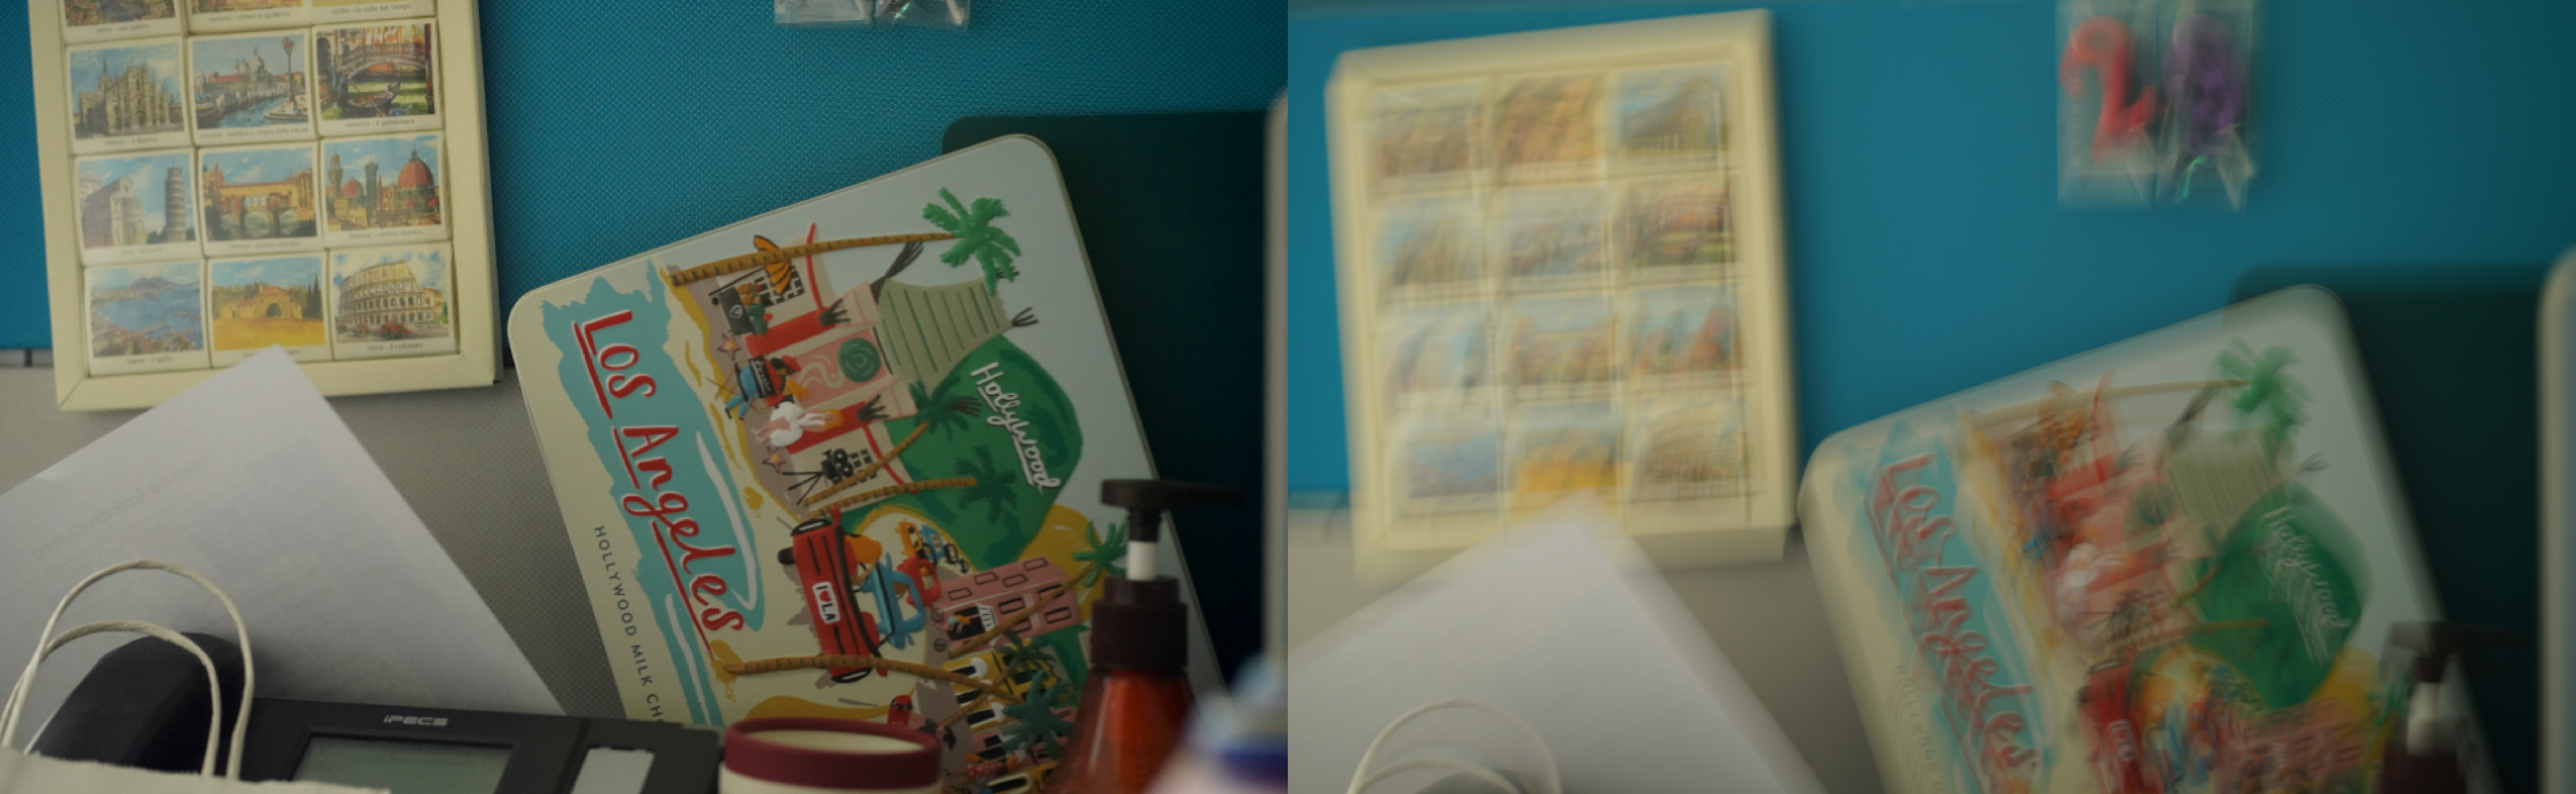
- 01/2026 Our paper BlurPoint is accepted to ICRA 2026!
- 01/2026 Our paper NPC is accepted to ICLR 2026!
Research

Teaching

- Co-supervisor, Undergraduate Final Year Project, 2019–2020
- Co-supervisor, MSc Project, 2019–2020
- Teaching Assistant, Multivariable Calculus for Engineers, Spring 2021
- Teaching Assistant, Complex Variables for Engineers, Fall 2020
- Teaching Assistant, Probability and Statistics for Engineers, Spring 2020
- Teaching Assistant (Lead), Introduction to Control Systems, Fall 2019
Talks
-
Trustworthy Geometric Perception: Certifiable Global Optimization and Robust Estimation. Slides can be found here.
- Fauna, Amazon, October 5, 2026
- Eastern Institute of Technology, Ningbo, September 3, 2026
- Best of ICRA Virtual Meetup, July 21, 2026
Academic Services
- Conference Reviewer: CVPR, ICCV, ECCV, ICML, NeurIPS, ICLR, ACM MM, AAAI, ICRA, IROS, BMVC, 3DV, WACV
- Journal Reviewer: TPAMI, IJCV, IJRR, TRO